Evaluation report, Small Underwater Objects 3D Point Cloud Dataset
We fine-tuned the same object recognition model twice, once on SUOP as released and once on an edited SUOP with the 130 recordings that return under 60% of their own setup's geometry removed, and the edited one scored 5.4 points higher over 800 held out scans.
Success rate by task
The eight tasks are object and range setups taken straight from the release, each held out at 100 scans. A same-size random cut scored 33.2%, so the gain is from which recordings were removed, not from removing recordings.
Gain per task
The setups that gain most are chair at 6 m and drum at 6 m, which is where the cut concentrated. The pooled lift clears zero, most single setups at 100 scans do not, and the chart says so.
What the edited version had removed
Measured on the release. Every recording is one object at one of three ranges, so the fifteen setups each hold between 100 and 110 repeats of the same shot, and a recording can be scored against its own repeats. The number is the size of its point_cloud.xyz over the median of that setup, and the median recording lands at 100%. The 130 recordings under 60% were dropped. They are not scattered, 89 of them form two unbroken opening blocks, drum at 10 m cases 001 to 044 and drum at 6 m cases 006 to 050, each returning about half the points that the later repeats of the identical setup return before the yield snaps back and stays there. Every setup keeps at least 56 recordings and every object keeps at least 218.
| Removed | recordings | points vs same setup |
|---|---|---|
| drum at 6 m, unbroken block from case_006 to case_050 | 45 | 46.7% |
| drum at 10 m, unbroken block from case_001 to case_044 | 44 | 50.2% |
| chair at 6 m, unbroken block from case_001 to case_017 | 17 | 31.5% |
| net at 10 m, unbroken block from case_001 to case_010 | 10 | 49.9% |
| dummy and tire, scattered | 14 | 50.4% |
| Removed | 130 | 47.9% |
| Kept | 1,424 | 100.5% |
The removed sonar frames
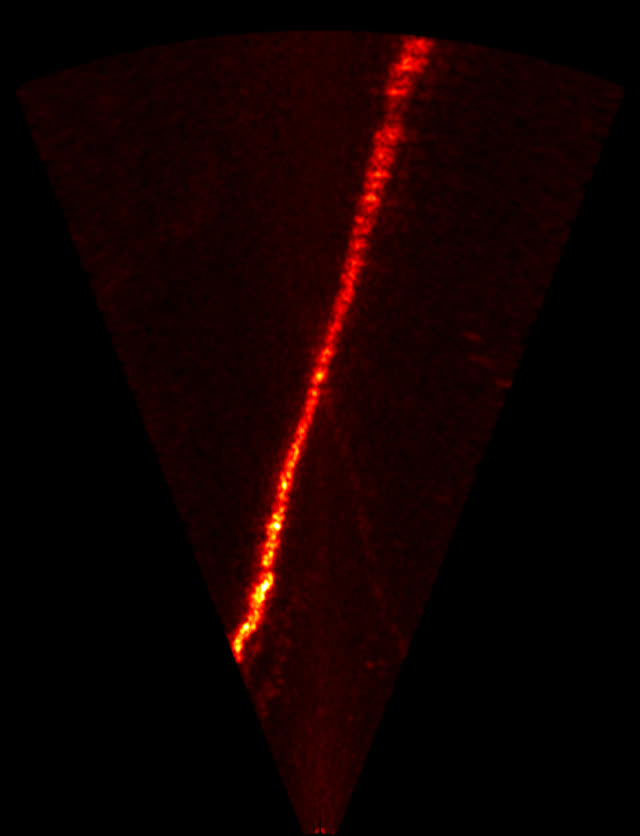
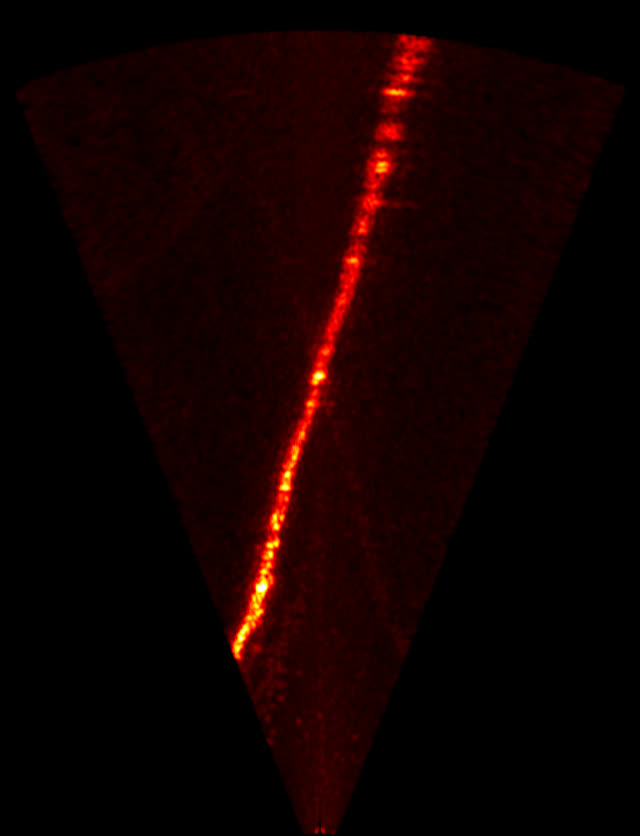
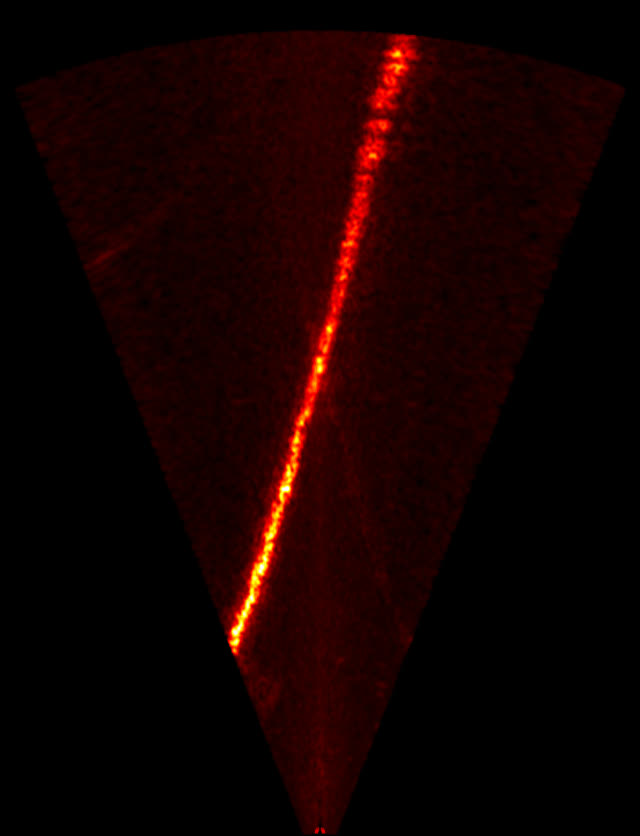
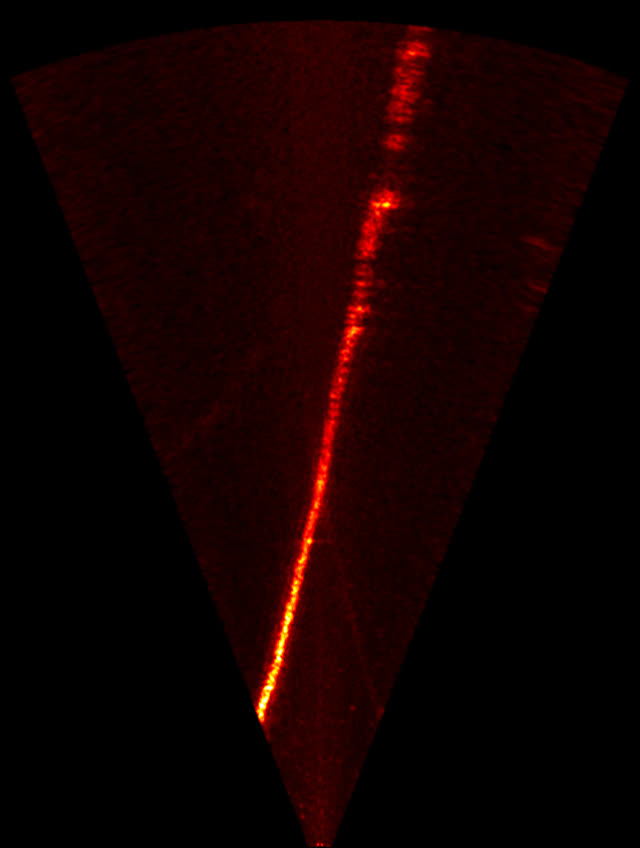
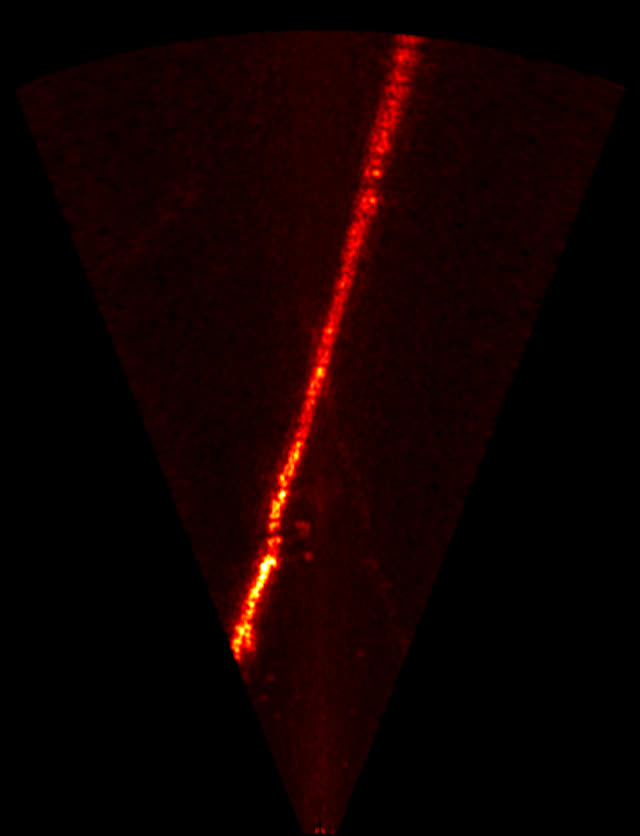
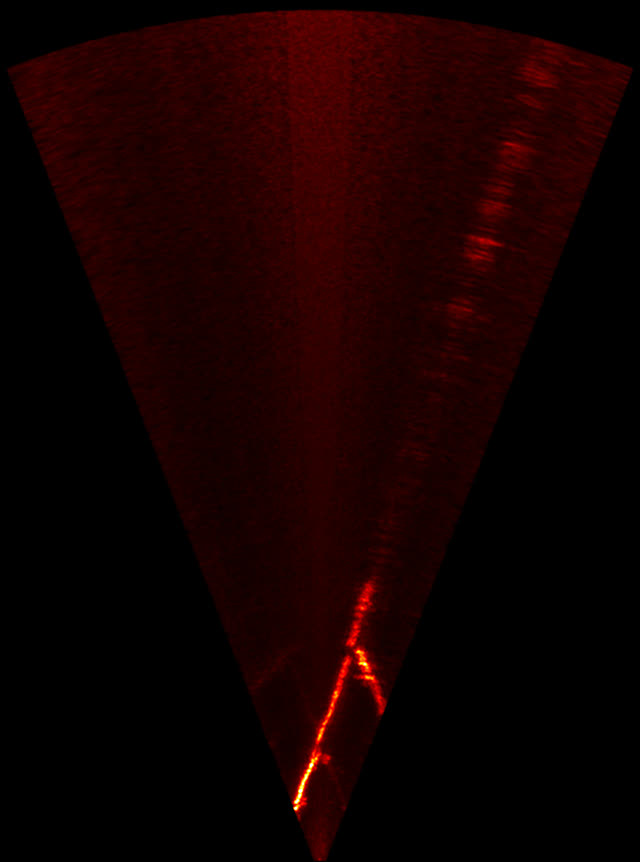
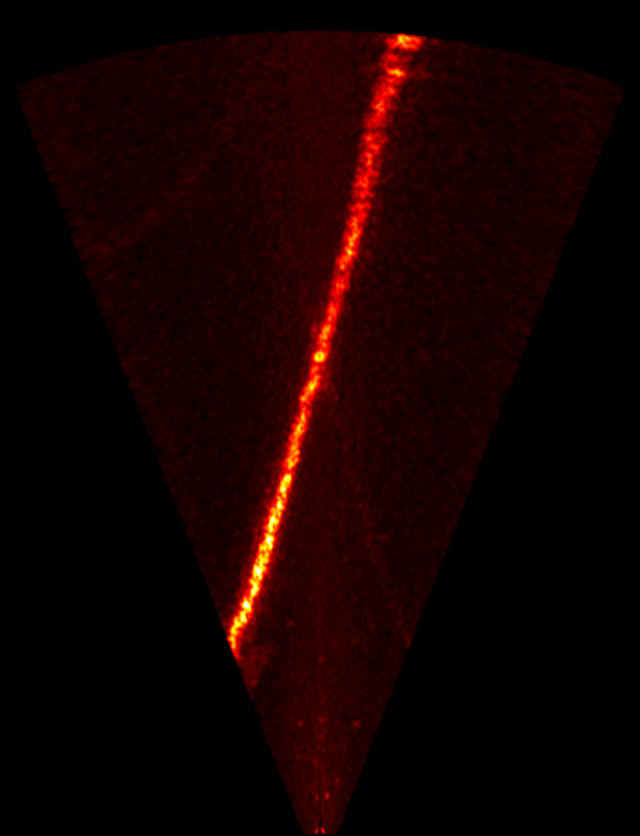
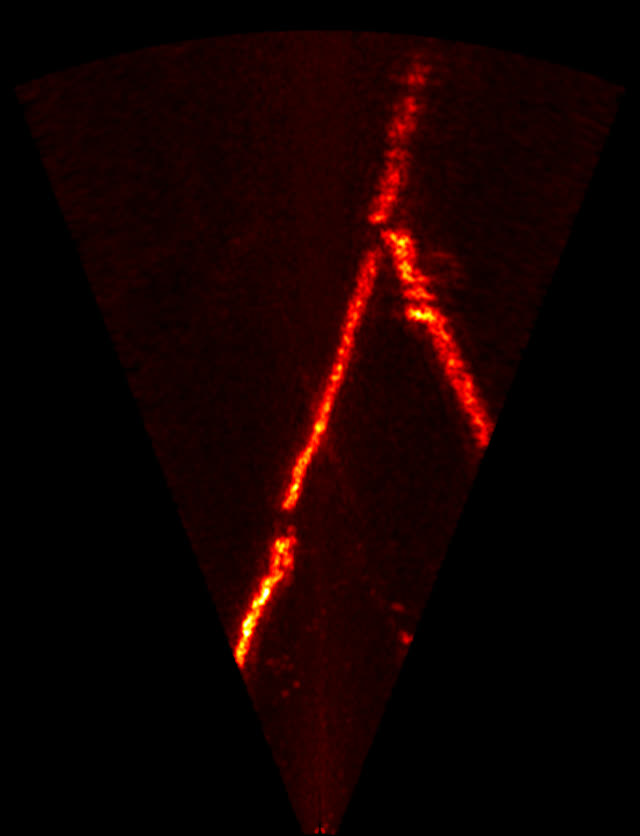
Measured on the release. Each card is the first of the ten sonar frames published for that recording, and the number is the size of its point cloud against the median of the other repeats of the identical setup.