Gantry

Evaluation report, cpaxton/pickup_pink_cup

We fine-tuned the same policy twice on cpaxton/pickup_pink_cup, once on the release as published and once with the 2 takes removed whose gripper command never covers the open to closed span the other 18 do, and the edited version scored 5.2 points higher across 600 graded rollouts.

FINE-TUNED ON FULL
19.5%
Task success with every episode.
CI 16.5 to 22.9 · n=600
FINE-TUNED ON EDITED
24.7%
Task success with the 2 takes that never cover the full gripper span removed.
CI 21.4 to 28.3 · n=600
LIFT
+5.2 pp
From training on less data.
95% range +0.5 to +9.8
REMOVED
10.1%
2 of 20 episodes, 260 of 2,587 frames.
43.3 s of 7 min 11 s
GRIPPER HELD OPEN
125 frames
Episode 7 holds the gripper command at 0.6000, its fully open value, on every frame while the arm runs a complete reach and lift.
1 unique value · finger moves 0.0001
ACTION VECTOR
10 wide
info.json names 9 joints. Channel 10 is undocumented and equals frame index over episode length on every frame.
agrees to 3e-8 · std 0.29092

Success rate by task

fine-tuned on full cpaxton/pickup_pink_cup fine-tuned on edited cpaxton/pickup_pink_cup

A same-size random cut of 2 takes scored 19.8%, so the gain is from which takes were removed, not from removing takes.

Gain per task

The pooled gain clears zero with a low end of +0.5 points. Two of the six stages come out flat on their own at this trial count, and the chart says so.

What the edited version had removed

Measured on the release. All 20 takes carry the same task string, the same operator field and the same environment field and were recorded inside one hour on 15 August 2024, so the only thing separating them is what the arm did. The per-episode number is gripper command travel, the distance the stretch_gripper channel covers inside a take, and it splits the release cleanly, 18 takes between 0.8199 and 0.8701 and two below 0.6200. Episode 7 holds the gripper at 0.6000, its fully open value, on all 125 frames, while the lift joint runs 0.5714 down to 0.2634 and back up to 0.5386, a travel of 0.3080 that sits inside the 0.2441 to 0.4312 the other takes cover, so the arm completed a pick with nothing in the hand. Episode 3 never opens past 0.3634 against the 0.5945 to 0.6000 the other 19 reach, so its whole approach happens with the hand part way shut. The cut is those two, 260 frames of 2,587. The three takes running 1.5 to 1.8 times the median 126 frames are kept, and so is the take whose gripper is closed on only 13 of its 127 frames, because a slow or clumsy demonstration that still closes on the cup is something a policy can learn from and a pick that grasps nothing is not. Two more channels carry nothing at all, base_y_joint and base_theta_joint are exactly 0.0000 on all 2,587 frames.

Removedepisodesframesgripper travel
Gripper commanded 0.6000 open on every frame11250.0000
Gripper never opens past 0.3634 of the 0.6000 open command11350.6183
Removed2260below 0.70
Kept182,3270.8199 to 0.8701

The removed media

Measured on the release. There is no video here, the two cameras are stored as one JPEG per frame at 6 fps, so each card is a single frame from the head or the gripper camera. The number on each card is the gripper command at that exact frame and the command travel of the take it comes from.
episode_007 frame 083 gripper
episode_007 frame 083 gripperremoved
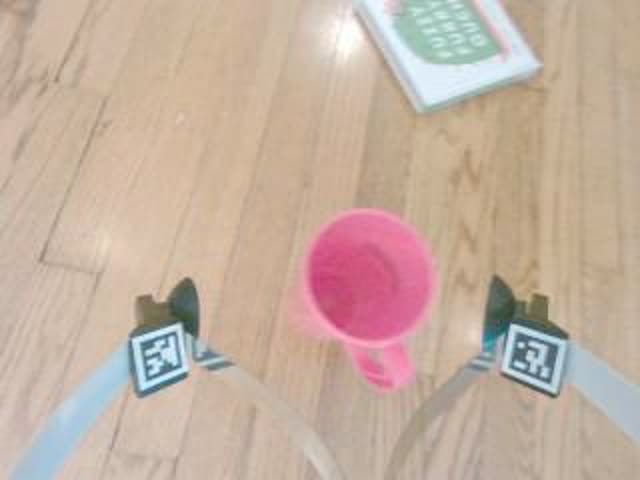
The lowest point of the reach, with the gripper still commanded fully open
row 991 · gripper commanded +0.6000 · lift at its lowest 0.2634 · take travel 0.0000
episode_007 frame 083 head
episode_007 frame 083 headremoved
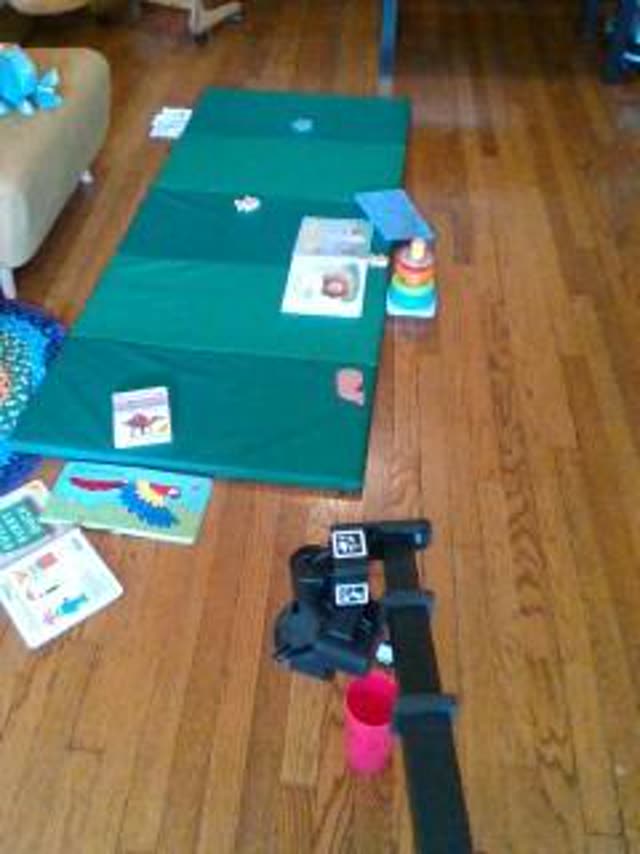
The same instant from the head camera, arm down over the cup
row 991 · gripper commanded +0.6000 · 83 of 125 frames elapsed · take travel 0.0000
episode_007 frame 040 gripper
episode_007 frame 040 gripperremoved
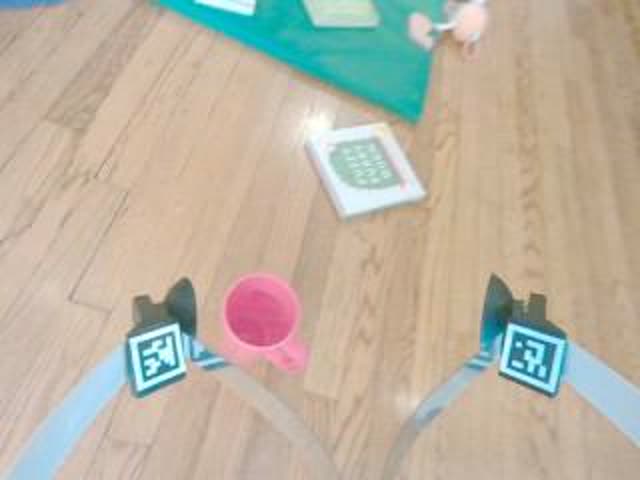
A third of the way through the descent and the gripper has not moved
row 948 · gripper commanded +0.6000 · lift 0.3320 · take travel 0.0000
episode_007 frame 124 gripper
episode_007 frame 124 gripperremoved
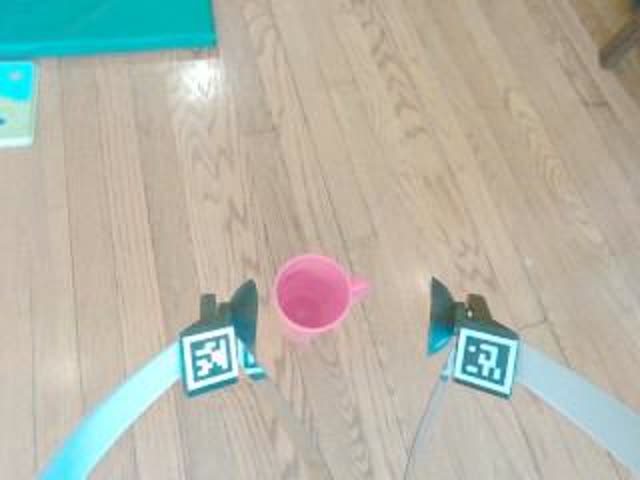
The last frame of the take, arm lifted away with the hand still wide open
row 1032 · gripper commanded +0.6000 · lift back up to 0.5386 · take travel 0.0000
episode_003 frame 022 gripper
episode_003 frame 022 gripperremoved
The widest this take ever opens, 0.3634 against the 0.6000 the other 19 use
row 471 · gripper commanded +0.3634 · lift 0.5233 · take travel 0.6183
episode_003 frame 000 head
episode_003 frame 000 headremoved
The first frame of the take, the hand already part way shut before the approach
row 449 · gripper commanded +0.3271 · 0 of 135 frames reach the 0.6000 open command
episode_000 frame 090 gripper
episode_000 frame 090 gripperkept
A kept take at the moment the fingers are fully closed on the cup
row 90 · gripper commanded -0.2175 · finger at -0.2319 · take travel 0.8442
episode_011 frame 219 gripper
episode_011 frame 219 gripperkept
The longest take in the release, 1.8 times the median, kept because it closes
row 1593 · gripper commanded -0.2414 · 224 frames · take travel 0.8414
cpaxton/pickup_pink_cup · 20 episodes · 2,587 frames at 6 fps · 6 stages × 100 rollouts Wilson 95% · cut = gripper command travel below 0.70