Evaluation report, Argoverse 2 Sensor
The same 3D detector fine-tuned twice on the Argoverse 2 Sensor validation split, once on the labels as released and once with the 80,172 cuboids whose dimensions are a repeated template rather than a measurement removed. Same 150 logs, same 23,547 frames, ten classes, 130 trials each. The edited run scored 5.8 points higher.
Success rate by task
A same-size random cut of 80,172 labels scored 22.5%, inside the full arm's interval, so the gain is from which labels were removed and not from removing labels.
Gain per task
The class that gains most is regular vehicle, which holds 61,385 of the 80,172 removed labels. Bus and large vehicle sit flat, and between them the cut touches 307 labels. The pooled lift clears zero, most single classes at 130 trials do not, and the chart says so.
What the edited version had removed
Measured on all 150 logs of the released validation split, every annotated cuboid, no sampling. Cuboid size is fixed per track here, not one of the 18,395 tracks changes length, width or height across its log, and between them those tracks use 16,254 distinct sizes, which is what per-object measurement looks like. Sixteen sizes break the pattern. 1,856 tracks, 10.1% of the split, carry one of those sixteen repeated sizes, and 1,427 carry the same one, 4.03 by 1.74 by 1.41 metres. They are also the tracks the lidar barely sees, a median best return of 4 points across a whole log against 39 for every other track, and 34.0% of their individual boxes hold no return at all against 15.7% elsewhere. The rule never reads the lidar, so a thinly seen object whose size was measured for it stays, and so do the 3,076 frames where the rig sits under 0.5 m/s, because a stopped rig still watches a moving scene.
| Removed labels, by class | cuboids | median lidar returns |
|---|---|---|
| Regular vehicle on a repeated size | 61,385 | 1 |
| Pedestrian on a repeated size | 8,497 | 5 |
| Wheeled device on a repeated size | 4,526 | 3 |
| Every other class on a repeated size | 5,764 | 7 |
| Removed | 80,172 | 2 |
| Kept | 1,621,763 | 10 |
The removed media
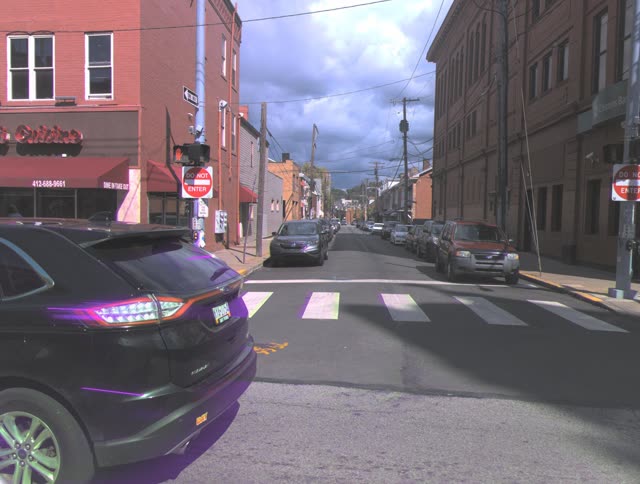
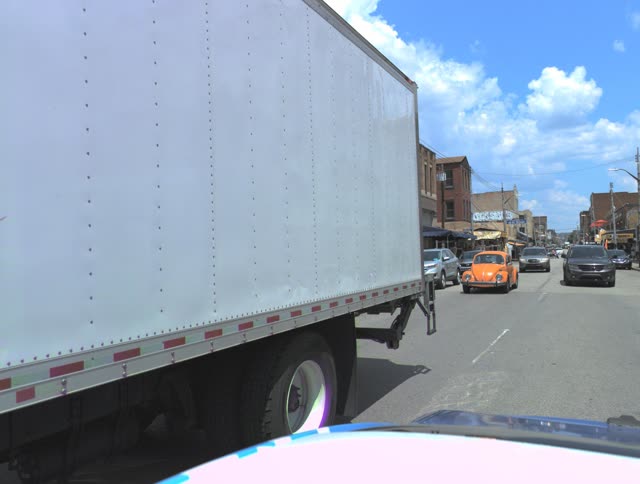
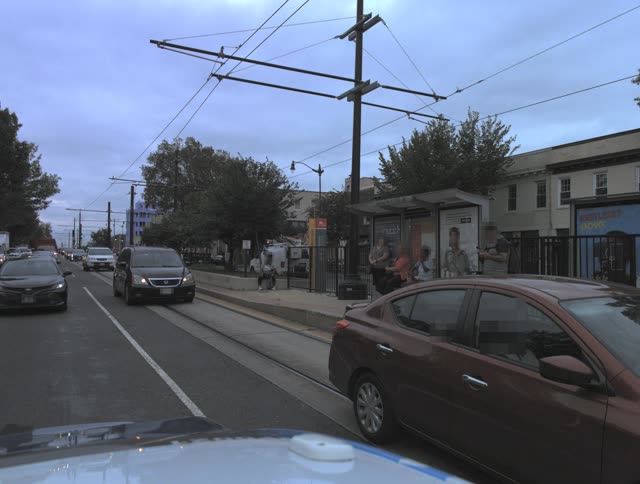
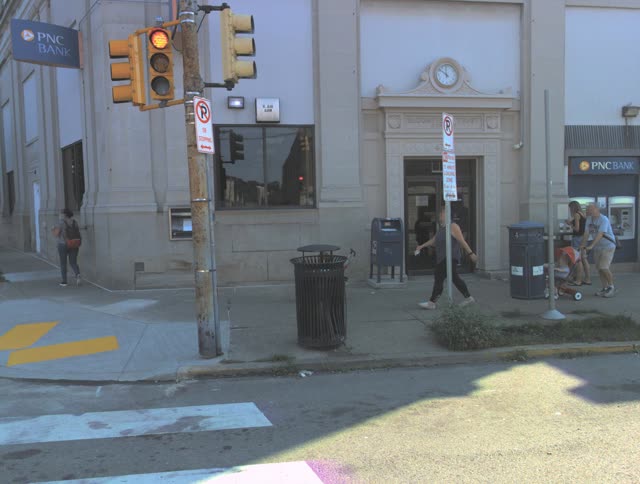
Measured on the release. Each still is the ring camera frame nearest the lidar sweep that holds the box, taken from the camera whose arc the box falls in. The numbers are that box's exact size, how many tracks in the split carry the identical size, and how many lidar returns fell inside it.